المبدع: @TheHumanoidHub ↗
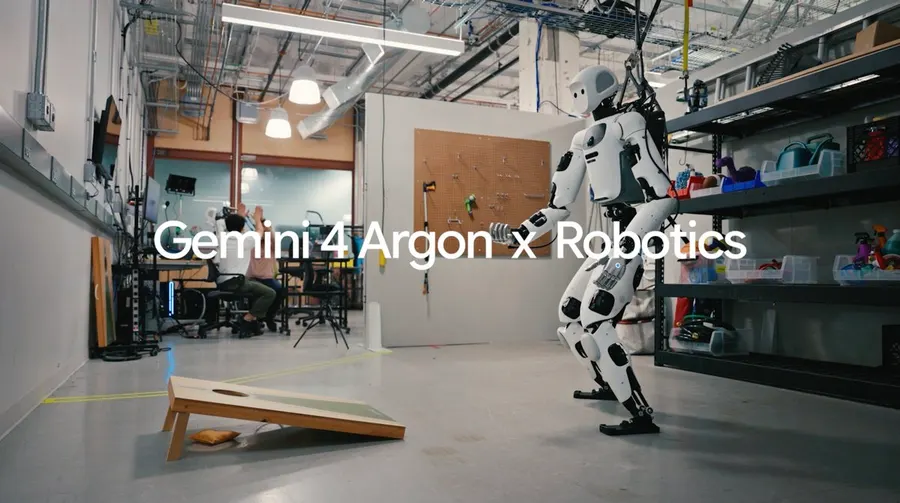
Physical robot throwing control through reasoning
ملاحظات المبدع
A generalist model, not a dedicated robot policy, pulled off physical control by reasoning and using tools. Here's the four-step approach Gemini 4 figured out, given high-level instructions and the overall task: 1. Watched a human throw, and mapped the motion to its own joints. 2. Used its cameras to locate the board in 3D, and built a physics sim. 3. Practiced in simulation, tuning its stance and swing for a smooth arc. 4. On the real robot, watched each landing and adjusted by centimeters until 7 shots went in.
المنشور الأصلي · @TheHumanoidHub ↗